See the legend below for the signal names used in the sequence charts on this page. Each state can be accessed via communication (the Ux.1 status value) or output by signal, except END, which is available only as an output signal.
|
Abbreviation |
Meaning |
Status Value |
Access |
|---|---|---|---|
|
INPOS |
In-position |
Ux.1=8 |
Via communication or output signal |
|
ALM |
Alarm output |
Ux.1=Alarm No. |
Via communication or output signal |
|
BUSY |
During operation |
Ux.1=0 |
Via communication or output signal |
|
STO |
STO |
Ux.1=1024 |
Via communication or output signal |
|
SRV |
Servo status |
Ux.1=16 |
Via communication or output signal |
|
END |
End |
— |
Only output signal |
Sequence When Power is On
The sequence below describes from when the main power is turned on until CM3 is ready to accept commands. This sequence applies only when the initial servo state is "Servo on".
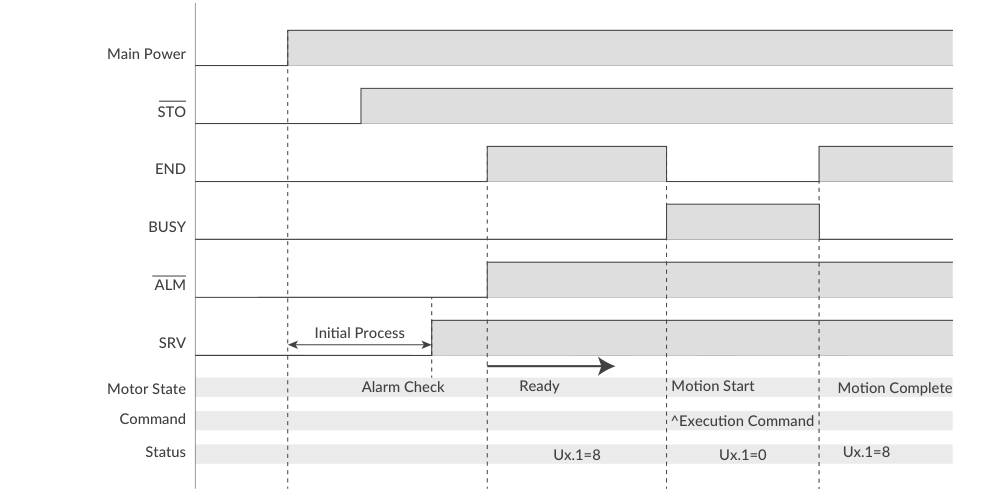
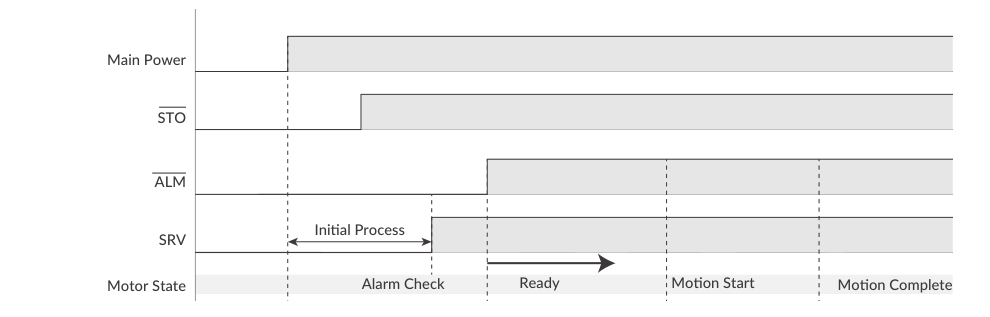
When the main power is turned on, the system checks that the STO function is off, then the servo is on. Next, the system checks the alarm status. When there are no alarms, the ALM and END outputs are turned off.
Pulse Type
CM3 is then ready for operation by pulse signal.
I/O Type
CM3 is then ready to accept the execution input signal.
Direct Type
CM3 is then ready to accept the execution command.
Sequence to Reset Alarm
The sequences shown below are for resetting an alarm.
Alarm Reset Sequence (Pulse Type)
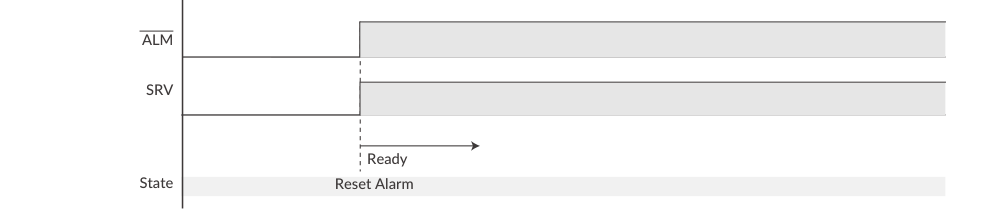
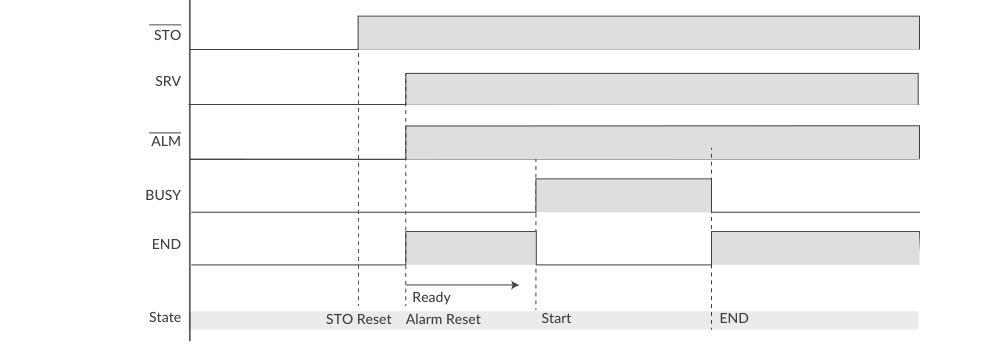
In case of alarm status, remove the cause of the alarm, then Servo On / Reset Alarm by a signal to Input 3. When an alarm is reset, CM3 becomes servo on and operation by pulse signal is possible.
Alarm Reset Sequence (I/O Type)
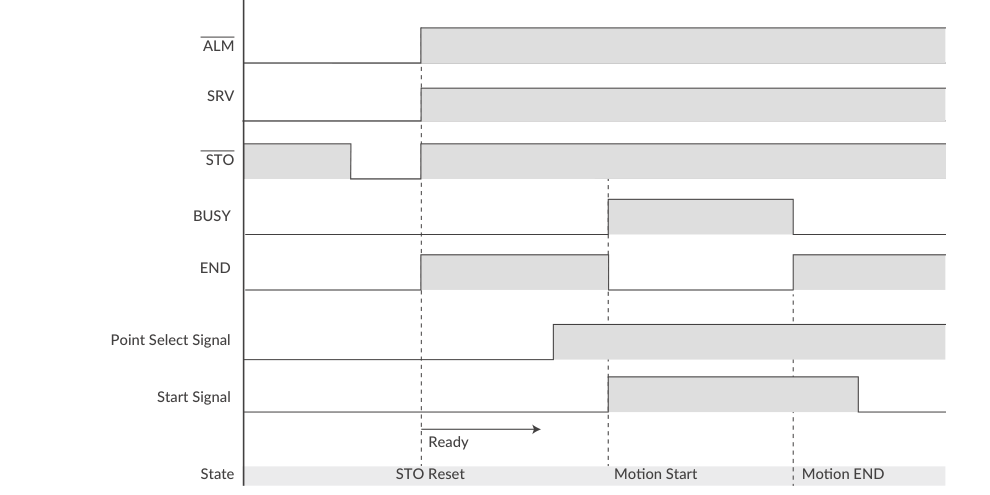
At the same time as the alarm is reset, the servo is turned on and the CM3 is ready to accept the operation execution signal.
Alarm Reset Sequence (Direct Type)
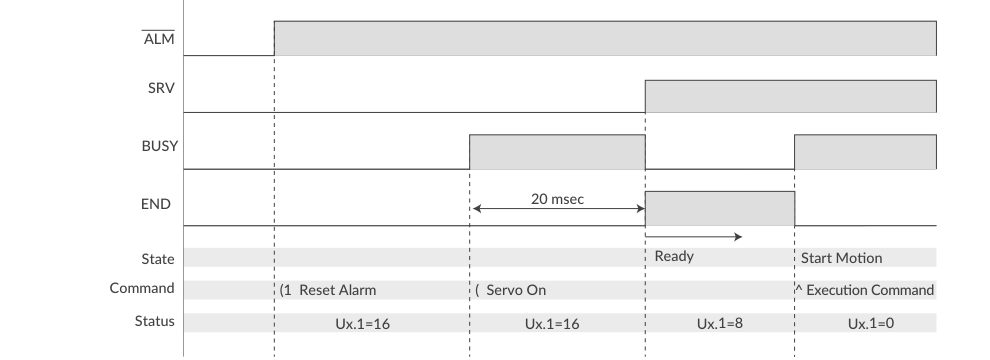
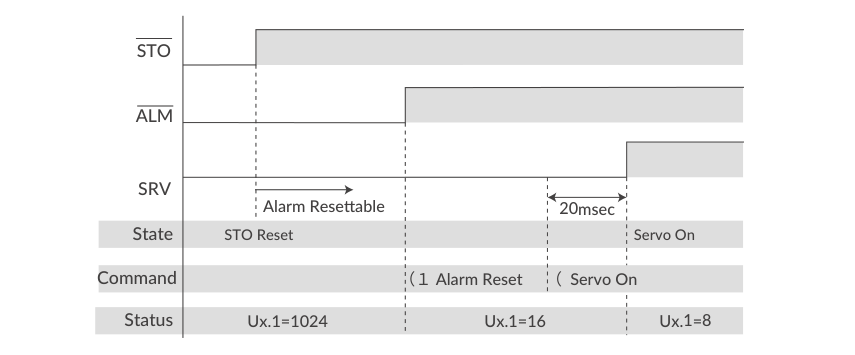
In case of alarm status, remove the cause of the alarm and reset the alarm. Then send the Servo On command after alarm reset and checking status. 20 msec after Servo On, CM3 will be ready to accept execution commands.
* If using an external brake, release the brake within this 20 msec.
Positioning Operation
Motion Data is composed of elements necessary for operation, such as speed, acceleration, target position, and torque. Motion Data can be registered and saved in CM3, and positioning operation is performed by selecting the Motion Data number and executing it. Absolute positioning (PTP Motion), relative positioning (INC Motion), and Push Motion are available.
Pulse Type
The Pulse Type does not position by Motion Data. Positioning is performed by pulse input signals — see Positioning by Pulse Input below.
Select Motion Data (I/O Type)
CM3 reads the input status of IN2 to IN4 by a 3-bit binary code to select the Motion Data. OFF=0 and ON=1 are used for calculation of selecting the Motion Data number as below.
-
IN2: 2⁰=1
-
IN3: 2¹=2
-
IN4: 2²=4
The Motion Data number is calculated by addition of the input status. For example, IN2: OFF, IN3: ON, IN4: ON ⇒ Selected Motion Data No. = 0 (IN2) + 2 (IN3) + 4 (IN4) = 6.
The Motion Data can be selected as shown in the below table.
|
Motion Data Number |
IN4 (Bit 2) |
IN3 (Bit 1) |
IN2 (Bit 0) |
|---|---|---|---|
|
0 |
OFF |
OFF |
OFF |
|
1 |
OFF |
OFF |
ON |
|
2 |
OFF |
ON |
OFF |
|
3 |
OFF |
ON |
ON |
|
4 |
ON |
OFF |
OFF |
|
5 |
ON |
OFF |
ON |
|
6 |
ON |
ON |
OFF |
|
7 |
ON |
ON |
ON |
The Motion Data No. is read by binary code and executed by applying a signal to IN6.
PTP Motion (Absolute Position) / INC Motion (Incremental Position) (I/O Type)
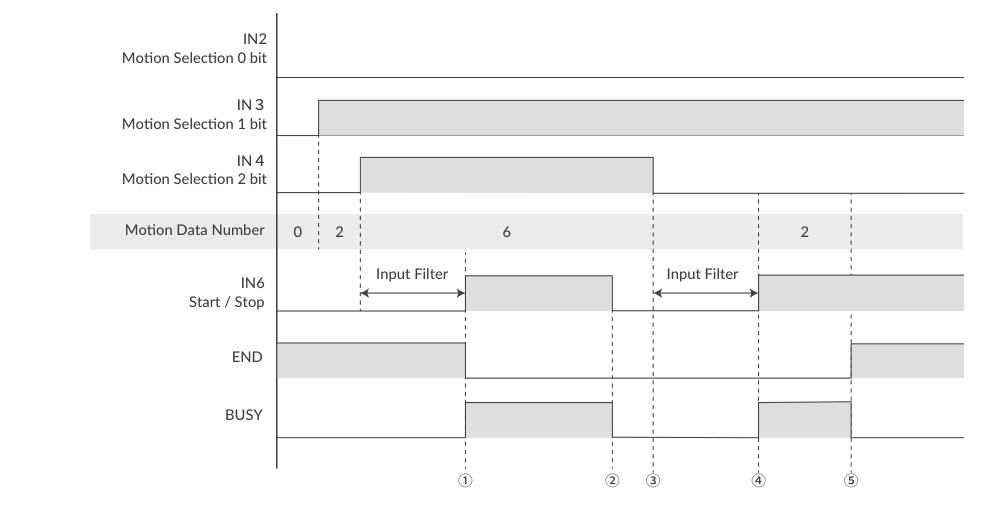
Set PTP Motion or INC Motion by the V command when setting the Motion Mode of each Motion Data. When performing PTP Motion / INC Motion, refer to the following sequence.
* END Output and BUSY Output are valid only when they are set to Output Function.
-
When selecting the Motion Data No., apply a signal to IN6 (Motion Execution signal) after the input filter time.
-
If IN6 is turned off (Motion Stop signal) before the motion is completed, END output is not turned on because CM3 did not reach the target position.
-
Without END output, CM3 starts to read the binary code of the input status at the rising edge of the signal to IN6. In the above sequence, Motion Data 6 is executed.
-
When changing the input state of IN6, please change it after the input filter time.
-
When the motion is completed, the END output is turned on.
Normal Positioning (Direct Type)
* PTP Motion means PTP (ABS directive), and INC Motion means PTP (INC directive).
PTP Motion Example — Set the below data to Motion Data 1.
V1=0                //Set PTP Motion to Motion Mode
P1=10000            //Set 10000 pulse to Position
S1=100              //Set 100 (Unit: K2) to Speed
A1=100              //Set 100 kpps² to Acceleration
^1                  //Execute Motion Data 1
INC Motion Example — Set the below data to Motion Data 1.
V1=1                // Set INC Motion to Motion Mode
P1=10000            // Set 10000 pulse to position
S1=100              // Set 100 (Unit: K2) to Speed
A1=100              // Set 100 kpps² to Acceleration
^1                  // Execute Motion Data 1
Sequence when Pause command is sent during INC Motion
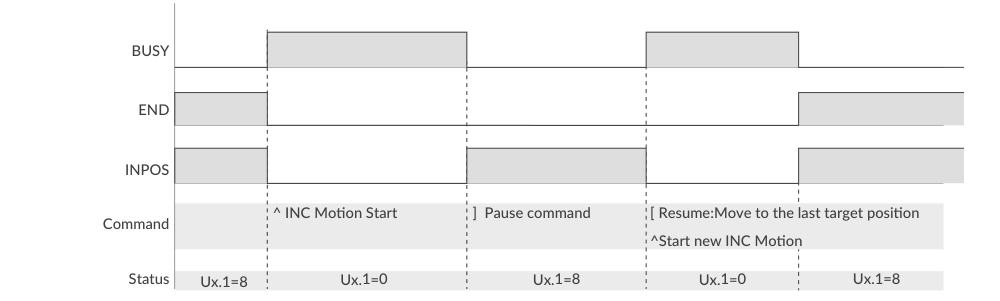
When the Pause command ( ] ) is sent during INC Motion, CM3 stops and In-position is detected. With the re-start command, CM3 goes to the former target position and the motion will be completed.
Sequence when stop command is sent during INC Motion
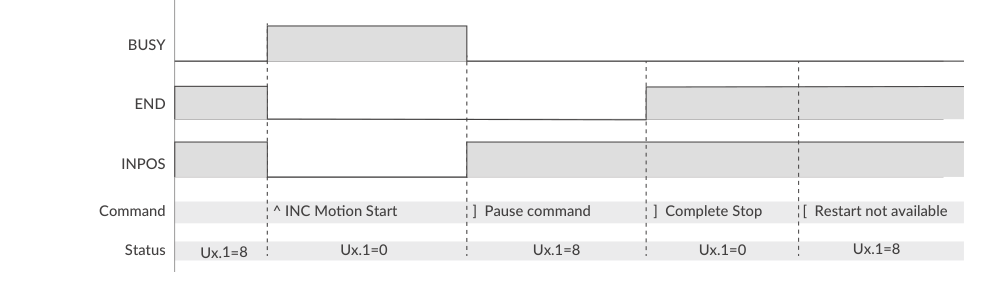
When the Pause command ( ] ) is sent during INC Motion, CM3 stops and In-position is detected. CM3 becomes stop = END status by sending the Pause command again and will not move even if the restart command is sent.
Positioning by Pulse Input (Pulse Type)
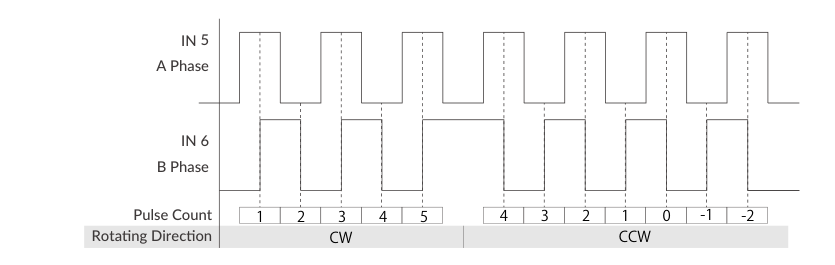
The below Pulse Input Methods are available for CM3. Select the method with the Pulse Input Method parameter (K41).
CW/CCW (K41=0)
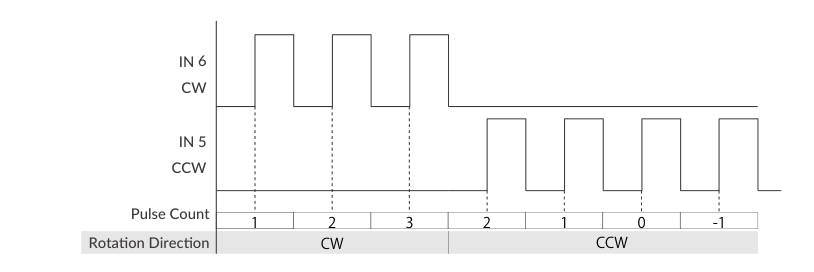
Step/Direction (K41=1)
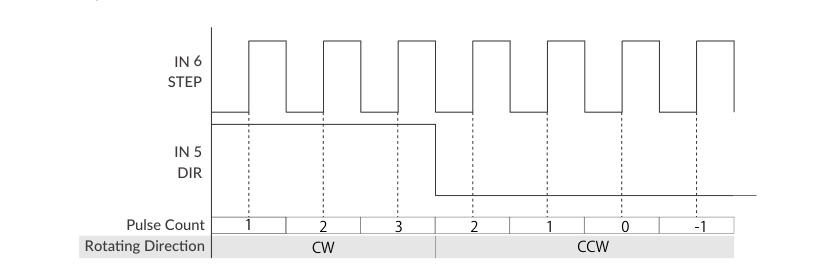
A Phase/B Phase (K41=2)
Push Motion (I/O and Direct Type)
The Push Motion is an operation that limits the output torque to the set torque for the set time. It can be used for gripping and press-fitting workpieces.
To execute the Push Motion, set the Motion Mode (V command), Push Torque (Q command), Push Motion Operation Mode (K11), and Push Motion Holding Time (K13).
PTP / INC Push Motion
Push Motion is available by setting the Motion Mode to PTP Push Motion (V=2) or INC Push Motion (V=3). The target position for Push Motion can be set to either PTP (absolute position) or INC (relative position).
-
PTP Push Motion: Starts the Push Motion from the current position toward the set absolute position.
-
INC Push Motion: Starts the Push Motion with the target position at the distance set from the current position.
In either case, set the target position so that it is several revolutions ahead of the object to be pushed. If the target position is too small, positioning may be completed before the workpiece is detected, or sufficient torque may not be generated.
Push Torque (Unit: % of rated torque)
Set the torque for Push Motion with the Q command.
Push Motion Operation Mode (K11)
Select the direction to limit torque and the finite (set time) / continuous Push Motion Holding time.
|
K11 |
Push Torque Direction |
Push Time |
|---|---|---|
|
0 |
One-direction |
Continuous |
|
1 |
One-direction |
Set time |
|
2 |
Both-direction |
Continuous |
|
3 |
Both-direction |
Set time |
-
Push Torque Direction — One direction: The Push Torque is effective only in the operation direction. This can be used to grip a rigid workpiece. Both direction: The Push Torque is effective in both directions. This can be used to grip an elastic workpiece or only detect a workpiece.
-
Push Motion Time — Continuous: Regardless of the Push Motion Holding Time (K13), the Push Motion doesn't stop until the stop command is sent. Set Time: When the total Push Time reaches the Push Motion Holding Time (K13), the Push Motion is completed.
Push Motion Holding Time (K13)
Set the time to continue the Push Motion. (Unit: msec)
Example:
K11=1                // Set Push Motion Operation Mode as One-direction and Set Time.
K13=3000             // Set Push Motion Holding Time as 3000 msec
V2=2                 // Set Operation Mode 2 as PTP Push Motion
P2=10000             // Set Target Position 2 as 10000 pulses
S2=20                // Set Speed 2 as 20 (Unit: K2)
A2=50                // Set Acceleration 2 as 50 kpps²
Q2=30                // Set Push Torque 2 as 30% of Rated Torque
I/O Type
Input 3: ON          // Select Motion Data 2
Input 6: ON          // Start Motion Data 2
Direct Type
^2 // Execute Motion Data 2
CM3 starts moving to the 10000 pulse position by the set acceleration and speed. CM3 goes into Push Motion when CM3's torque reaches 30% of the rated torque and the status goes into Push Motion status (Ux.1=32). Push Motion is completed when the total time of Push Motion goes up to 3000 msec. After the completion of Push Motion, torque remains at the torque set by the Push Motion Torque and the status becomes Ux.1=40 (=32+8).
I/O Type
The set torque remains until the Motion Stop signal is turned on or the next Motion Data is executed.
Direct Type
The set torque remains until the Pause command is sent or the next Motion Data is executed.
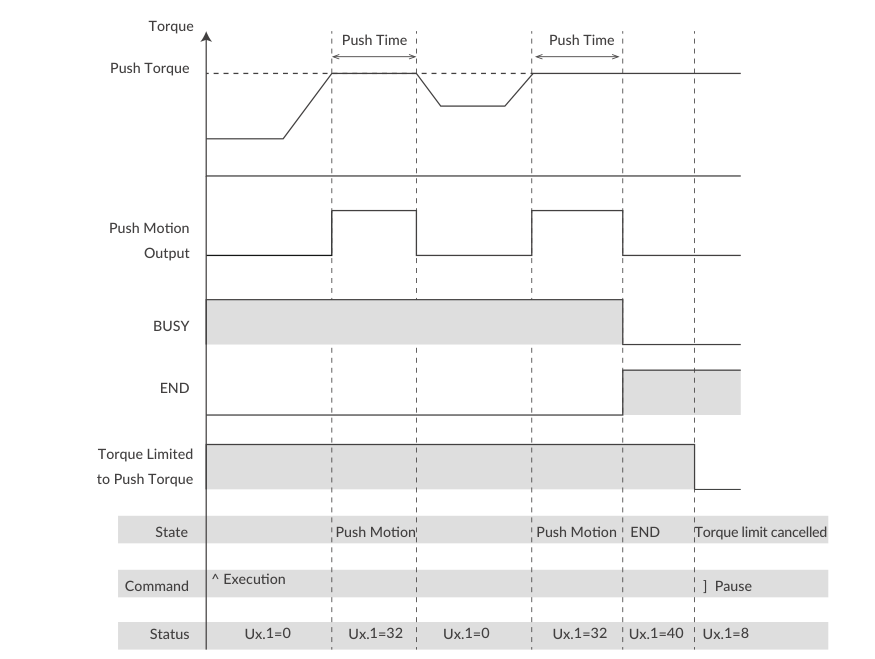
If the object to be pushed cannot be detected during the Push Motion and CM3 reaches the set target position, Ux.1=296, which is the total of the Operation Warning Ux.1=256, Push Motion Ux.1=32, and In-position Ux.1=8, will be output. Sending the warning information Query command ?199, the Push Motion Warning, WARN.1=1 is replied.
To Resume Push Motion (Direct Type)
If the Pause command is sent during the Push Motion, motion will be paused but the Push Motion Holding Time will not be cleared. Paused Push Motion will be resumed when the re-start command is sent.
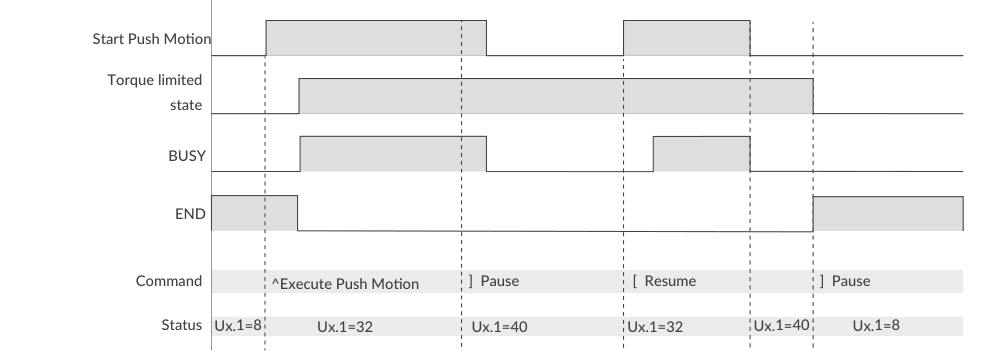
To Execute Next Motion (Direct Type)
If the Pause command is sent twice during Push Motion, Push Motion will be terminated and the torque limit is canceled.
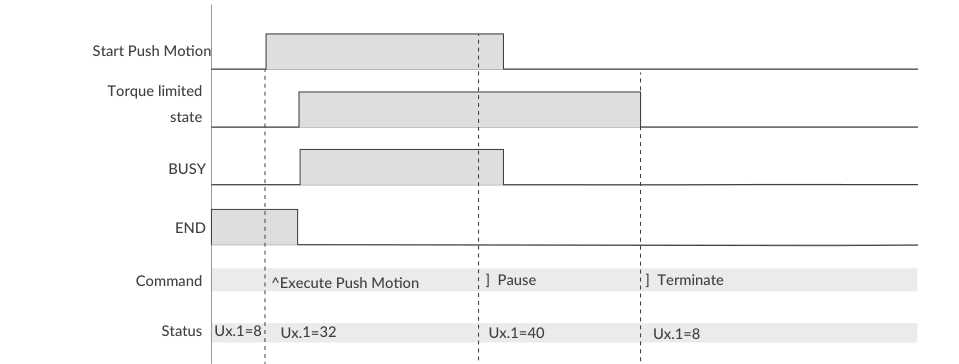
Signal output is valid only when the function is assigned to an output by Output Function Selection.
Push Motion by Torque Limit (Pulse Type)
CM3 can continuously push or grip an object by this function. By turning on Input 4, the output torque can be limited to the torque set by K12. The limitation is off when Input 4 is off. Apply the pulse signal so as not to overflow the Position Error Overflow Threshold when using this function. When disabling this function, send a pulse signal in the opposite direction and make sure that CM3 has moved away from the object.
Origin Detection (I/O and Direct Type)
Origin Detection can be selected from Stopper Detection, Origin Sensor, Z Phase Signal and combinations, as shown in the below table.
|
K22 |
Content |
|---|---|
|
0 |
Stopper Detection |
|
1 |
Stopper Detection (Auto) |
|
2 |
Origin Sensor * |
|
3 |
Origin Sensor (Auto) * |
|
4 |
Stopper Detection + Z Phase Signal |
|
5 |
Stopper Detection + Z Phase Signal (Auto) |
|
6 |
Origin Sensor + Z Phase Signal * |
|
7 |
Origin Sensor + Z Phase Signal (Auto) * |
|
8 |
Z Phase Signal |
|
9 |
Z Phase Signal (Auto) |
* Valid only when the origin sensor is assigned to Input 1
Category of Origin Detection
-
Stopper Detection: Origin Detection using a mechanical stopper
-
Origin Sensor: Origin Detection using an origin sensor
-
Z Phase Signal: Origin Detection using a Z phase signal of CM3
-
Auto: Origin Detection starts automatically when the power is turned on.
Set the following parameters as needed to perform origin detection:
-
Settings for Origin Detection Motion: Origin Detection Speed (K23), Origin Detection Acceleration (K24), Origin Detection Direction (K25)
-
Settings for Offset: Origin Offset Distance (K26), Origin Offset Distance Unit (K27)
-
Settings for Stopper Detection: Stopper Detection Torque (K28)
-
Setting for Origin Sensor: Input 1 Function (K44)
-
Settings for Origin Detection Completion: Origin Detection Completion (K30), Output Function (User Defined) (K54), Origin Set Completion Output (K55, K56, K57)
I/O Type
Origin Detection Execution (K21): To start the Origin Detection using the input signal, enable the Origin Detection Execution setting (K21=1). Then, the Origin Detection is assigned to Motion Data 0.
K21=1        // Enable origin detection start

IN2 / IN3 / IN4: OFF
IN6: ON to Execute Origin Detection
Stopper Detection
If the device to which the CM3 is installed has a mechanical stopper, the origin search is available using the stopper as the origin signal source.
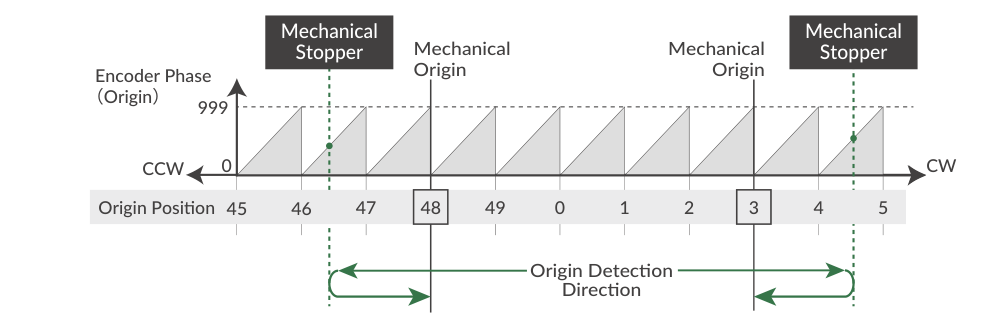
There are 50 origin positions (mechanical origins) per rotation when using Origin Detection Stopper Detection. The encoder phase shifts from 0 to 999 linearly between each origin position.
When Origin Detection is started, CM3 starts rotating in the set direction to detect the stopper. Stopper detection will be completed when the motor torque reaches the Stopper Detection Torque and the speed becomes 1/16 of the Origin Detection Speed. CM3 then displays the encoder phase information (Origin=0 to 999).
After stopper detection, Origin Detection is completed at the encoder phase 0 point that is 1 cycle before the phase detected by the stopper. Phase 0 is not related to Z phase.
-
Set the threshold of the torque to detect a stopper for Origin Detection by percentage of Max. Torque.
-
When the Stopper Detection Torque is set too low, the origin is mis-detected by detecting torque reaching the threshold.
-
When Origin Offset is set, the position moved the set offset distance from the detected mechanical origin is the coordinate origin.
-
For a stable origin search, adjust an attachment such as a coupling so that the encoder phase value indicated in "Origin=***" is between 200 and 800.
Origin Sensor
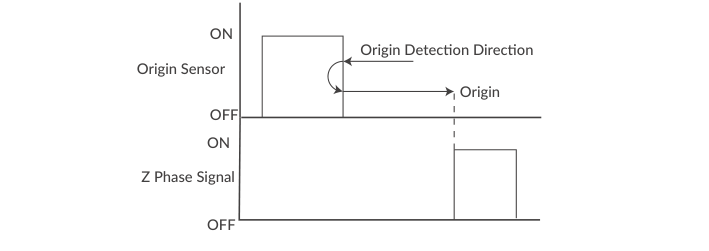
The Origin Sensor signal can be assigned only to IN1. The sensor signal detection circuit is a hysteresis circuit to minimize noise influence. The rising edge of the origin sensor in the Origin Detection Direction is detected as the mechanical origin.
* If the origin detection is executed when the origin sensor is not assigned to Input 1, Ux.1=264, which is the total of the operation warning Ux.1=256 and in-position Ux.1=8, is output, and WARN.1=32 (operation warning) is output when the warning Query command ?199 is sent. When selecting the Input 1 function of K44, be sure to select the origin sensor (K44=1) or the limit sensor in the origin detection direction (K44=2: CCW limit sensor, K44=3: CW limit sensor).
Depending on the status of the origin sensor signal when Origin Detection starts, there are the following differences in the Origin Detection operation.
When the origin sensor signal is OFF when Origin Detection is executed
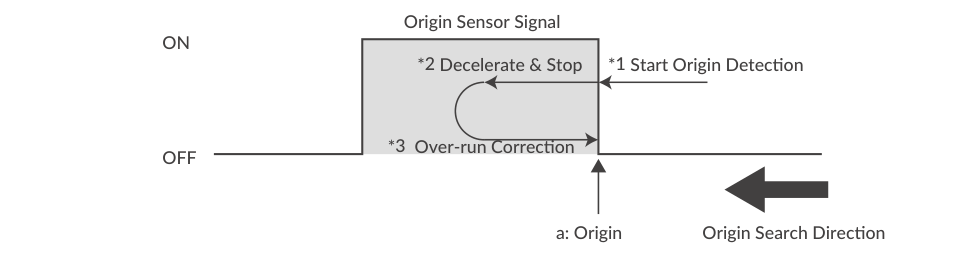
-
Start origin detection
-
Decelerate from the rising edge (a) of the origin sensor (Point a) (*2)
-
Move to Point a again (*3). Complete origin detection
When the origin sensor signal is ON when Origin Detection is executed
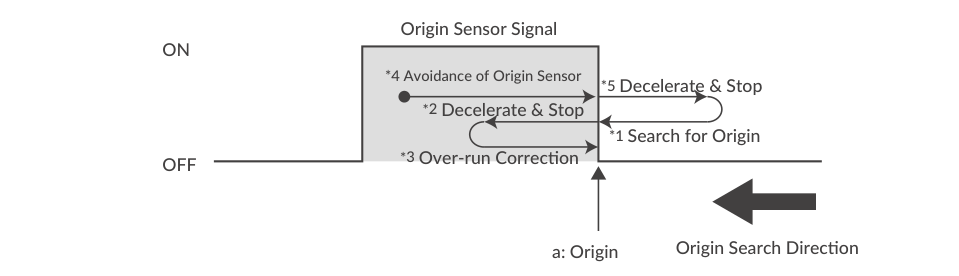
-
Run in the opposite direction to the origin detection direction to get out of the origin sensor
-
After passing the point a and detecting the sensor signal off in the figure, start to decelerate (*5)
-
The same motion as "When the origin sensor signal is OFF" in the previous paragraph will be executed
-
Start origin detection
-
Decelerate from the rising edge of the origin sensor (Point a) (*2)
-
Move to Point a again (*3). Complete origin detection
Simultaneous use of limit sensor and origin sensor
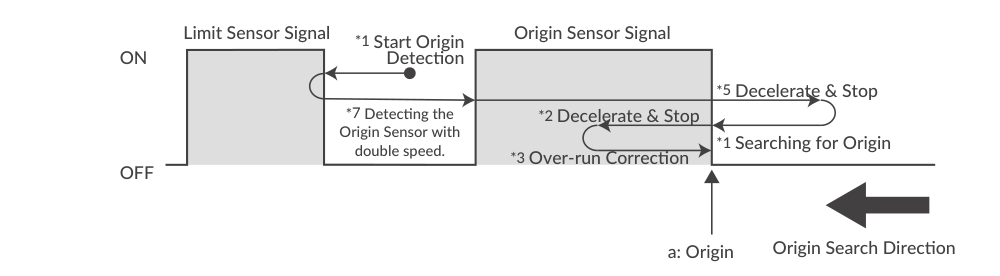
-
Start Origin Detection.
-
When the limit sensor signal in the origin detection direction is detected, start moving in the opposite direction at twice the origin detection speed.
-
Detect the origin sensor signal (*7).
-
After detecting the origin sensor signal, the same motion as "When the origin sensor signal is ON" in the previous paragraph will be executed.
-
To move out of the sensor signal, move in the opposite direction from the origin detection direction.
-
After passing the point a in the figure, start to decelerate after detecting the sensor signal off (*5).
-
The same motion as "When the origin sensor signal is OFF" in the previous paragraph will be executed.
-
After starting origin detection, decelerate from the rising edge of the origin sensor (Point a) (*2).
-
Move to Point a again (*3). Complete origin detection
Z Phase Signal
The Z-phase signal is output once per rotation based on the internal encoder information. Origin Detection using Z-phase signals can always have the same origin in one rotation of the output shaft, so it is possible to omit the sensor in applications such as rotary tables.
* Origin Offset is ignored when using Z Phase Signal.
Simultaneous use of Origin Sensor / Stopper Detection and Z Phase Signal
It is possible to detect an origin by a combination of Stopper Detection / Origin Sensor and the Z Phase signal. After detecting an origin by Stopper Detection / Origin Sensor, CM3 moves in the opposite direction of the Origin Detection Direction and sets the first Z Phase Signal as the coordinate origin.
Input Functions
CM3 has 6 inputs. The assignment of each input depends on the control type, as shown in the comparison table below. Configurable inputs are noted with their selection parameter; all other input functions are fixed.
|
Input |
Pulse Type |
I/O Type |
Direct Type |
|---|---|---|---|
|
1 |
CCW Limit Sensor (stops motion in the CCW direction) |
Limit ・ Origin Sensor — select origin sensor (1) or CCW (2) / CW (3) limit sensor direction with K44 |
Limit ・ Origin Sensor — select origin sensor (1) or CCW (2) / CW (3) limit sensor direction with K44 |
|
2 |
CW Limit Sensor (stops motion in the CW direction) |
Motion Data Selection (bit 0) |
Limit Sensor — select CCW (2) / CW (3) limit sensor direction with K45 |
|
3 |
Servo On / Alarm Reset — turn Servo On/Off; alarm is reset after Servo On |
Motion Data Selection (bit 1) |
Servo On / Alarm Reset — toggle Servo On / Servo Off; alarm can be reset when the servo is turned on |
|
4 |
Torque Limit On/Off — limit the maximum torque to the value set by K12 |
Motion Data Selection (bit 2) |
Manual Mode — switch to Manual Mode |
|
5 |
Pulse input (CCW / DIR / A Phase depending on K41) |
Limit Sensor — select CCW (2) / CW (3) limit sensor direction with K48 |
CCW Inching ・ Jog — Inching/Jog in the CCW direction in Manual Mode |
|
6 |
Pulse input (CW / STEP / B Phase depending on K41) |
Motion Execution / Stop — execute and stop the selected Motion Data |
CW Inching ・ Jog — Inching/Jog in the CW direction in Manual Mode |
For Motion Data selection by IN2 to IN4 (I/O Type), see Positioning Operation. For the pulse inputs (Pulse Type), see Positioning by Pulse Input in Positioning Operation.
Input Filter
Set the filter time for the input signal with K42 between 1 and 50 msec. The higher the number, the longer the filter time and the slower the response to the input. Signals shorter than the set value will not be recognized as input signals.
Example:
K42=5 //Set the filtering time for the input signal to 5 msec
Manual Mode (Direct Type)
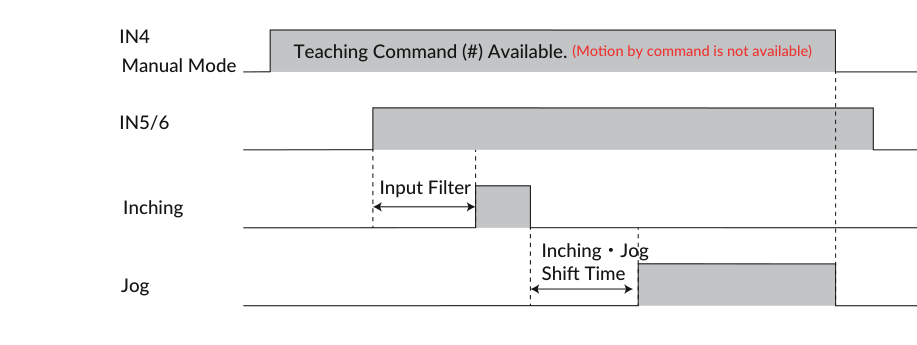
By turning on Input 4, CM3 goes into the Manual Mode. In this mode, Input 5 and 6 allow Inching and Jog motion. The execution command is not available in the Manual Mode.
Inching ・ Jog
Inching and Jog are possible by input signals. IN5 is for the CCW direction, and IN6 is for the CW direction. When an input signal comes in, CM3 moves the Inching Distance of K51 (1 to 100 pulses) at the speed set by K50 (1 to 32767 [unit: K2]).
After that, the motion will switch to Jog after the Inching ・ Jog Shift Time set by K52 (1 to 3000 msec). If the applied input signal is shorter than K52, only the Inching motion will be executed.
Example:
K2=0                 // Set speed unit as 100 pps
K50=50               // Set Inching / Jog Speed as 50 x [100 pps]=5000 pps
K51=100              // Set Inching Distance as 100 pulses
K52=1000             // Set Inching Shifting time as 1000 msec
When IN5 (IN6) is turned on, CM3 moves 100 pulses in the CW (CCW) direction as Inching. If IN5 (IN6) is continuously turned on for 1000 [msec] or more even after the operation is completed, the motion will switch to the Jog operation and continue rotating at a speed of 5000 [pps].
Jog
Set the speed for Jog by the Inching ・ Jog Speed parameter when the signal is applied.
Example:
K2=0                 // Set Speed Unit as 100 pps
K50=100              // Set Inching ・ Jog Speed as 10000 pps
K52=0                // Only Jog will start
Jog motion is executed in the CCW direction by a signal to IN5 and in the CW direction by a signal to IN6. CM3 keeps rotating at a speed of 10000 pps while the input is ON.
* If K52=0 is set, only Jog operation is enabled. Refer to "Inching ・ Jog Shift Time" for details.
Teaching
The Teaching function is to capture the current position into position data. While Manual Mode is on, move CM3 to a specific position by Inching / Jog with a signal to Input 5 and 6, then set the position to Motion Data by the # command. The sequence of Teaching Mode is the same as the Inching ・ Jog sequence shown above.
Example:
#19 // Capture current position into Motion Data 19 (P19)
* In Manual Mode, the Software Limit function is disabled.
Servo On / Servo Off
Pulse Type
CM3 can be Servo On (Alarm Reset) / Off by turning Input 3 on/off by a signal. When Input 3 is on, Reset Alarm and Servo On are executed at the same time, then CM3 sends the state Ux.1=8 (In-position). When Input 3 is off, CM3 sends the state Ux.1=16 (Servo Off).
I/O Type
Use the STO function to Servo on/off the I/O Type CM3. Refer to Sequence to Reset Alarm for details.
Direct Type
IN3 can toggle Servo On (alarm reset) and Servo Off. When the signal is turned on, the alarm is reset and the servo is turned on at the same time, and the status Ux.1=8 (In-position) is replied. When the signal turns off, the servo turns off, and CM3 replies the status Ux.1=16 (Servo Off).
Limit Sensor
Pulse Type
The functions of the limit sensors are fixed to Input 1 (CCW) and Input 2 (CW).
I/O Type
The function of the limit sensor can be set for Input 1 and Input 5.
K44=2      // Set CCW direction limit sensor to Input 1
K48=3      // Set CW direction limit sensor to Input 5
Direct Type
The function of the limit sensor can be set for Input 1 and Input 2.
K44=2      // Set CCW direction limit sensor to Input 1
K45=3      // Set CW direction limit sensor to Input 2
When the limit sensor turns on, CM3 sends Operation Warning (Ux.1=256) and the motor stops at the deceleration set in the Motion Data. The limit sensor warning (WARN.1=4) is returned with the Warning Information Query command ?199. After stopping, CM3 can only move in the opposite direction of the limit sensor.
Torque Limit (Pulse Type)
By turning on IN4, the torque limiting function is enabled. During torque limitation, the maximum torque is limited to the torque set by K12 and the Torque Limit Output is turned on. Turning IN4 off removes the maximum torque limit.
* The Torque Limit Output is available only when the output function is assigned.
Output Functions
CM3 has 4 outputs. Functions can be assigned to Output 1–3, though Output 4 is fixed to ALARM output.
Either ABZ Encoder Output or User Defined can be selected as the function for Output 1–3. It is recommended that ABZ Encoder Output is selected for a host controller to control CM3, and User Defined is selected for CM3 to output its status.
Each output function can be set by the Output Function parameter. This section explains each output function. Refer to the timing charts for the timings.
Alarm Output
The alarm output function is assigned to Output 4. CM3 goes into Servo Off when an alarm occurs to protect CM3. Alarm information can be confirmed by Status LED or by the reply (see Query Commands on the CML (COOL MUSCLE Language) page) to Query command ?99. Refer to Sequence to Reset Alarm for the sequence to cancel an alarm.
ABZ Encoder Output
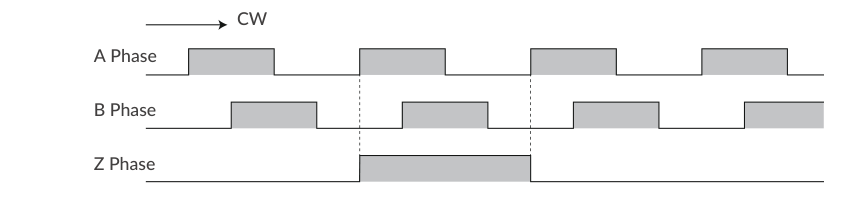
When the output function is set to "ABZ encoder output" (K54=0), OUT1 to 3 are assigned to the ABZ phase encoder output function. The Z phase is output once per rotation, and the relationship between the AB phase and the Z phase is as follows.
Related parameters: Resolution (K1), Output Function (K54)
The resolution of the ABZ output is fixed at 3000 ppr when the Resolution parameter is set to 3000 ppr or higher. If the Resolution parameter is less than 3000 ppr, the resolution of the ABZ encoder output will be the same as the Resolution parameter.
Other Output Functions
By selecting "User defined" for the output function (K54=1), 3 out of 11 kinds of output function can be assigned to Output 1, 2, and 3. Select the function of Output 1 with K55, Output 2 with K56, and Output 3 with K57.
|
K55/K56/K57 |
Function |
Output Contents |
Applies to |
|---|---|---|---|
|
0 |
General Output |
Turn outputs on / off by command |
All |
|
1 |
In-position Output |
Output in the In-position range |
All |
|
2 |
Warning Output |
Output in the Operation and Status Warning state |
All |
|
3 |
Individual ZONE Output |
Output in the ZONE set by Motion Data |
I/O ・ Direct |
|
4 |
ZONE Output |
Output in the ZONE set by parameters |
I/O ・ Direct |
|
5 |
MOVE Output |
Output when speed exceeds MOVE Output Threshold |
All |
|
6 |
BUSY Output |
Output during motion |
I/O ・ Direct |
|
7 |
END Output |
Output when operation is completed |
I/O ・ Direct |
|
8 |
Servo On |
Output when Servo On |
All |
|
9 |
Push Motion Output |
Output when torque exceeds the set value during Push Motion |
I/O ・ Direct |
|
9 |
Torque Limit Output |
Output when Torque Limit is active by a signal to Input 4 |
Pulse |
|
10 |
Origin Set Completion Output |
Output when origin is set |
I/O ・ Direct |
Positioning Status Output (In-position, BUSY, END)
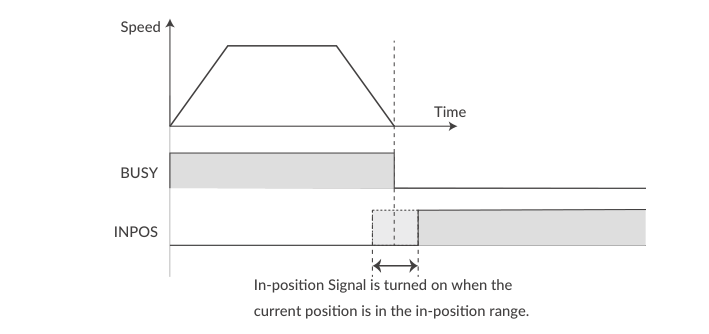
CM3 goes into In-position status and outputs a signal from the Output to which In-position Output is assigned when the current position goes into the In-position range (±) set by the In-position Range parameter (K5).
Pulse Type
The In-position signal is turned off when the deviation between the input pulse and the current position is greater than the In-position range.
I/O Type
When END Output is assigned, the output turns on when the operation set in the Motion Data is completed. When the operation is paused, In-position Output is turned on but END Output is not turned on.
Direct Type
When END Output is assigned, the output turns on when the operation set in the Motion Data is completed. When the operation is paused, In-position Output is turned on but END Output is not turned on.
Individual ZONE / ZONE / MOVE Output
-
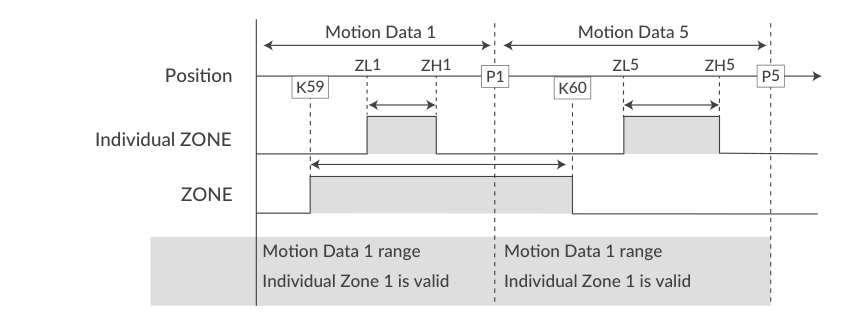
Individual ZONE Output (I/O and Direct Type): The output is turned on when CM3's current position goes into the zone set by Individual ZONE (-) (ZL) and Individual ZONE (+) (ZH) in each Motion Data. The Individual ZONE Output is valid from Motion Data execution, and the signal is on until the next Motion Data positioning is executed.
-
ZONE Output (I/O and Direct Type): The output is turned on when CM3's current position goes into the set zone. The ZONE Output range is set by ZONE (-) (K59) and ZONE (+) (K60), and this function is valid for all operation.
-
MOVE Output (all types): The output turns on when the speed set by the MOVE Output Threshold (K58) is exceeded. This output signal can be used as an operating signal.
All output signals are valid only when the output function is assigned to the output point.
Tuning
The servo tuning method can be selected from Tuningless or PPI control with the Tuning parameter (K31).
Tuningless (K31=1)
When selecting Tuningless by the Tuning parameter, CM3 is automatically optimized for changes of load, motion, etc. from the low to high speed range. When some adjustment of trackability is necessary, it can be adjusted by the Servo Stiffness parameter. The higher the Servo Stiffness value, the higher the trackability, but setting it too high will cause motor vibration.
PPI (K31=0)
In case of fixed load and operation, PPI Control can be selected by the Tuning parameter. When selecting PPI Control, the Position P gain, Speed P gain, and Speed I gain are valid. These gains can be separately set by parameters and are to be matched to your machinery and CM3 servo motor. Without gain adjustment, CM3 may exhibit vibration, an over-sensitive condition, and some noise.
Follow the steps below to adjust CM3's Position P gain, Speed P gain, and Speed I gain values. An adjustment with CM3 mounted in the machine and running the motor is necessary to find the optimum values.
① Initial Setting
Set parameters as follows.
Position P gain=100
Speed P gain=150
Speed I gain=1
② Speed P Gain (K34)
First, in order to optimize the Speed P Gain, increase the K34 value so that high-frequency vibration does not occur during CM3 operation. If the value of this parameter is too large, high frequency vibration may occur, but it is more stable to set K34 as high as possible.
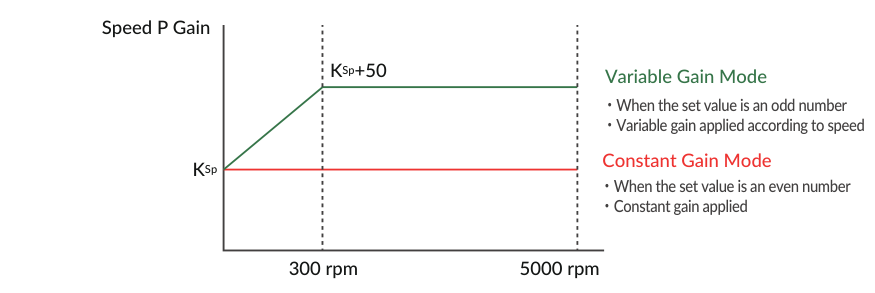
For variable gain mode, this gain setting value applies when the speed is 0 rpm. When the speed is between 0 rpm and 300 rpm, the Speed P gain value increases in proportion. The conclusive gain value is the set gain value plus 50.
* If the gain value is even, the Constant Gain Mode is set, and if the gain value is odd, the Variable Gain Mode will be set.
③ Position P Gain (K33)
After setting the optimum value of Speed P Gain, search for the optimum value of Position P Gain while operating CM3. Increasing the value of Position P Gain will reduce the position error. In other words, the positioning time will be shorter, but if the value of Position P Gain is too large, vibrations may occur. The higher the value as much as possible, the more stable the motion will be.
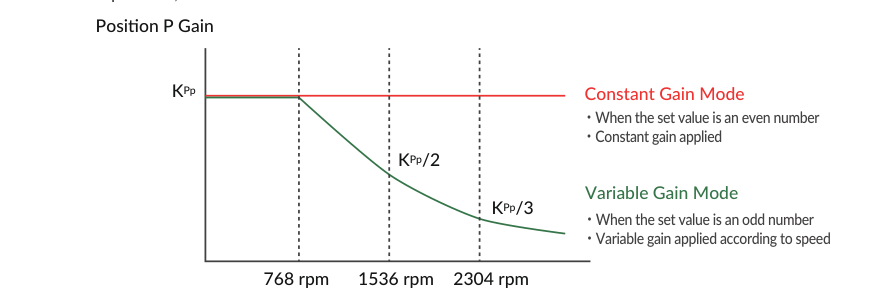
In the variable gain mode, the set value is the gain applied during low speed operation. The gain starts decreasing after the speed exceeds 768 rpm, and at 2304 rpm it becomes one-third of the set value. For example, if you set K33=101, 100 will be applied at speeds below 768 rpm, then at 3000 rpm, 25 will be applied.
* If the gain value is even, the Constant Gain Mode is set, and if the gain value is odd, the Variable Gain Mode will be set.
④ Speed I Gain (K35)
After setting the optimum value of Position P Gain, increase the value of Speed I Gain. Find the optimum value while operating CM3. Speed I Gain is a parameter for slowly correcting the position error when the position error is not sufficiently reduced even if the Position P Gain is adjusted. If the value of Speed I Gain is excessively high, a large vibration might occur.
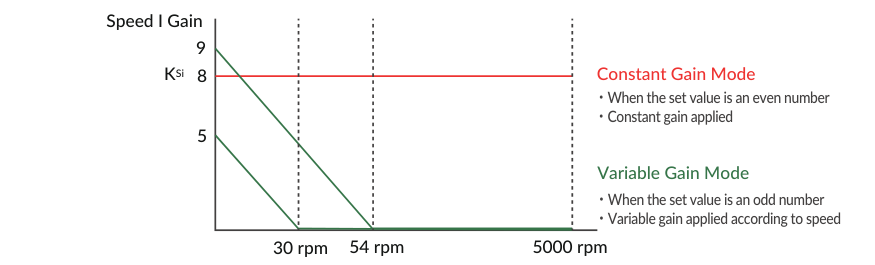
In variable gain mode, Speed I Gain decreases with increasing speed. When K35=5, Speed I Gain becomes 0 above 30 rpm, and when K35=9, it becomes 0 above 54 rpm.
* If the gain value is even, the Constant Gain Mode is set, and if the gain value is odd, the Variable Gain Mode will be set.
The optimal values can be set by following the above steps.
S-Curve Gain (I/O and Direct Type)
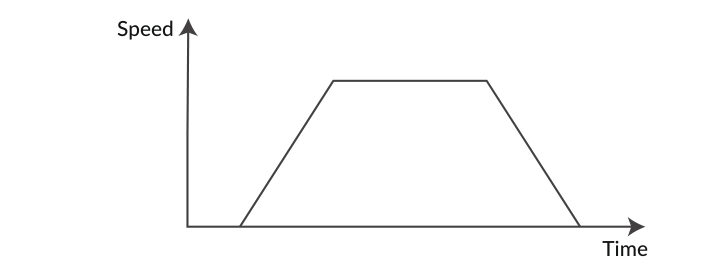
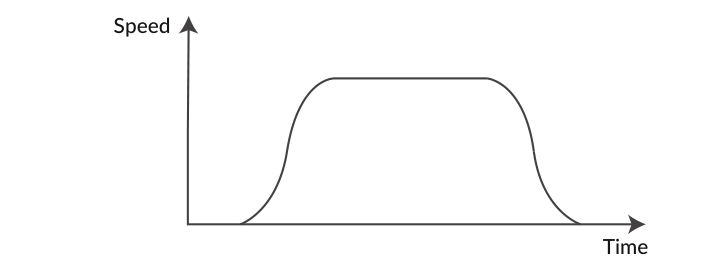
The S-curve gain (K36) is the parameter to change the trapezoidal motion to an S-shape. K36 can be set from 0 to 1024, and the higher the K36, the more the motion is S-shaped. Enabling the S-curve gain helps to soften the impact when starting and stopping, and to reduce overshoot.
Example:
K36=0 //Trapezoidal Motion
K36=1024 //S-Curve Motion
STO Function
CM3 is equipped with the STO (Safe Torque Off) function, which is one of the safety functions defined in the international standard IEC61800-5-2. STO is a function that cuts off only the power supply to the motor. When the STO function is activated, the stopped state of the motor is not controlled and the servo is turned off.
* Not certified by a third party organization
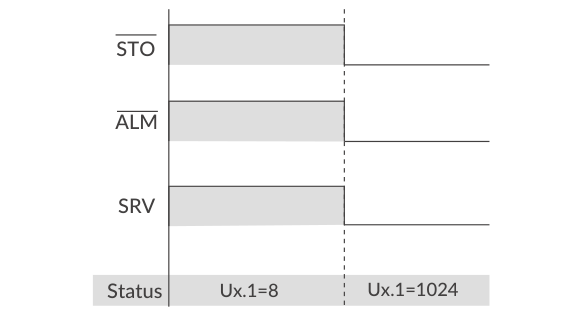
If a voltage is applied between STO+ and STO-, the STO stays disabled and CM3 is ready to operate. When the voltage is cut off, the STO is activated and CM3 goes into the STO (Ux.1=1024) status. When the voltage is applied again between STO+ and STO-, the STO is canceled and the alarm can be canceled. Please refer to Sequence to Reset Alarm to cancel the alarm.
Sequence for STO
Recovery sequence from STO state
Streaming Data (I/O and Direct Type)
The Streaming Data function periodically outputs data such as the current position, speed, and torque. Up to 4 types of data, from CH0 to CH3, can be sent at the same time.
Output Format: 01,[CH0],[CH1],[CH2],[CH3]
Streaming Data Selection (K85 to K88)
The data that can be set for CH0 (K85), CH1 (K86), CH2 (K87), and CH3 (K88) are as follows.
|
K85/K86/K87/K88 |
Output Data |
Unit |
|---|---|---|
|
0 |
Disabled |
- |
|
1 |
Target Position |
Pulse |
|
2 |
Current Position |
Pulse |
|
3 |
Target Speed |
K2 |
|
4 |
Current Speed |
K2 |
|
5 |
Target Torque |
% of Max. Torque |
|
6 |
Current Torque |
% of Max. Torque |
|
7 |
Load Factor |
% of Rated Torque |
|
8 |
Voltage |
0.1 V |
|
9 |
Temperature |
℃ |
|
10 |
Input Status |
- |
|
11 |
Output Status |
- |
Streaming Interval (K89)
I/O Type
The data streaming interval can be checked with K89. It is fixed at 100 msec and cannot be changed.
Direct Type
The data output interval is set with the Streaming Interval parameter (K89). Setting the Streaming Interval to 5 msec or less can cause the interval to become unstable.
Streaming Setting (K90)
Set streaming on / off and the timing when it is on with the Streaming Setting (K90). K90 always returns to "Disabled" (K90=0) when the power is turned on again.
|
K90 |
Name |
Details |
|---|---|---|
|
0 |
Disabled |
No Data Streaming |
|
1 |
Streaming all the time |
Stream data all the time. To stop the streaming, set K90=0. |
|
2 |
Streaming while operation |
Stream data only when the motor is running. Otherwise, no data is streamed. |
Streaming Data Example
[Sent Data]
K85=1          // Set Target Position for CH0
K86=2          // Set Current Position for CH1
K87=4          // Set Current Speed for CH2
K88=6          // Set Current Torque for CH3
I/O Type
K90=2          // Set Streaming Setting as "2: Streaming while operation"
               // Execution Signal
Direct Type
K89=100        // Set Streaming Interval as 100 msec
K90=2          // Set Streaming Setting as "2: Streaming while operation"
^              // Execution Command
[Received Data]
  0 msec: 01,0,0,0,0
100 msec: 01,495,494,10200,4
200 msec: 01,1495,1495,10080,2
300 msec: 01,2494,2495,9960,3
400 msec: 01,3495,3496,10200,3
500 msec: 01,4494,4495,10200,1
Status LED
The status of CM3 is indicated by the status LED with 7 colors (blue, green, red, magenta, cyan, yellow, white). The flashing pattern of the status LED for each status is as follows. If multiple statuses occur at the same time, the status closer to the top of the table has higher priority. Statuses that exist only for certain control types are marked in the Applies to column.
|
Status |
Pattern |
LED Color(s) |
Applies to |
|---|---|---|---|
|
STO |
Lighting |
Red |
All |
|
Overload Alarm |
Alternate |
Red ・ Magenta |
All |
|
Over Current Alarm |
Alternate |
Red ・ Green |
All |
|
Over Temperature Alarm |
Alternate |
Red ・ Cyan |
All |
|
Over Voltage Alarm |
Alternate |
Red ・ Blue |
All |
|
Low Voltage Alarm |
Alternate |
Red ・ White |
All |
|
Position Error Overflow Alarm |
Flashing |
Red |
All |
|
ABS Alarm |
Alternate |
Red ・ Yellow |
I/O ・ Direct |
|
Servo Off |
Lighting |
Magenta |
All |
|
Push Motion Warning |
Flashing |
Yellow |
I/O ・ Direct |
|
Limit Sensor |
Alternate |
Green ・ Yellow |
All |
|
Software Limit |
Alternate |
Blue ・ Yellow |
I/O ・ Direct |
|
Manual Mode Warning |
Lighting |
Yellow |
Direct |
|
Operation Warning |
Alternate |
White ・ Yellow |
All |
|
Overload Warning |
Alternate |
Magenta ・ Yellow |
All |
|
Temperature Warning |
Alternate |
Cyan ・ Yellow |
All |
|
Servo On |
Lighting |
Blue |
All |
|
BUSY |
Lighting |
Green |
I/O ・ Direct |
|
Push Motion |
Flashing |
Green |
I/O ・ Direct |
|
Torque Limit |
Flashing |
Blue |
Pulse |
|
In The Manual Mode |
Alternate |
Blue ・ White |
Direct |
* LED lighting for BUSY means motion is being executed. It may not match the BUSY output during operation (Ux.1=0). Please confirm the exact status by communication.