Overview
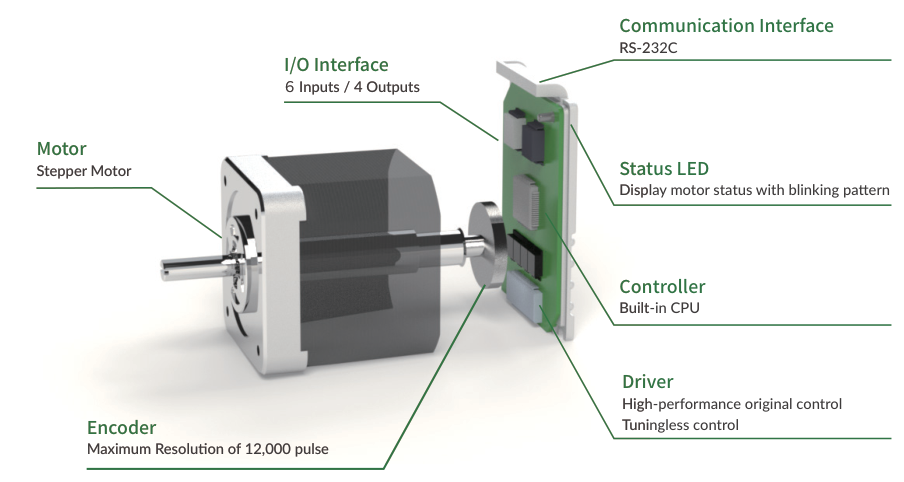
The CM3 is an integrated AC servo system with a built-in motor, encoder, driver, and controller. The higher torque and speed have been achieved by MUSCLE's own control technology. With MUSCLE's own programming language "CML" (COOL MUSCLE Language), various motion, such as PTP Motion, torque control and etc. can be set, and motion is executed by pulse signals (Pulse Type), by input signals (I/O Type), or via RS-232C serial communication (Direct Type). CM3 provides the highest solution.
Main Functions of CM3
-
PTP Motion (on the Pulse Type: PTP Motion by Pulse Input Signal)
-
Continuous Motion (I/O and Direct Type)
-
Push Motion (I/O and Direct Type)
-
Origin Detection (I/O and Direct Type)
-
Software Limit (I/O and Direct Type)
-
Torque Limit Function (Pulse Type)
-
STO (Safe Torque Off) Function
-
Tuningless Function
-
Various Output Functions (on the Pulse Type: ABZ-phase output and other output functions)
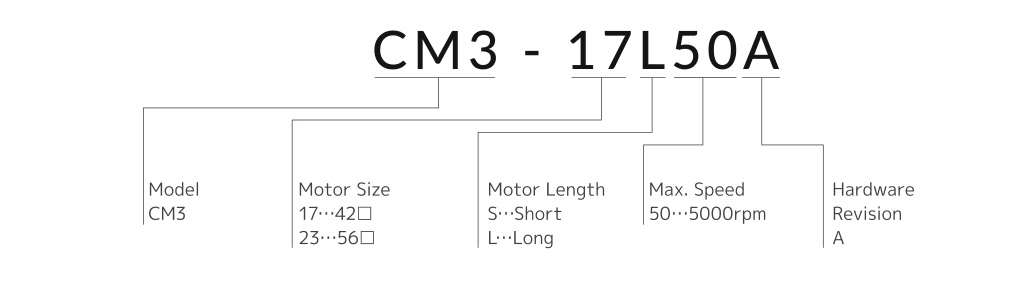
Product Code Scheme
CM3's product code scheme is described as below.
Product Name
|
Product Name |
Product Code |
|---|---|
|
CM3 42mm Short |
CM3-17S50A |
|
CM3 42mm Long |
CM3-17L50A |
|
CM3 56mm Short |
CM3-23S50A |
|
CM3 56mm Long |
CM3-23L50A |
Function Block Diagram
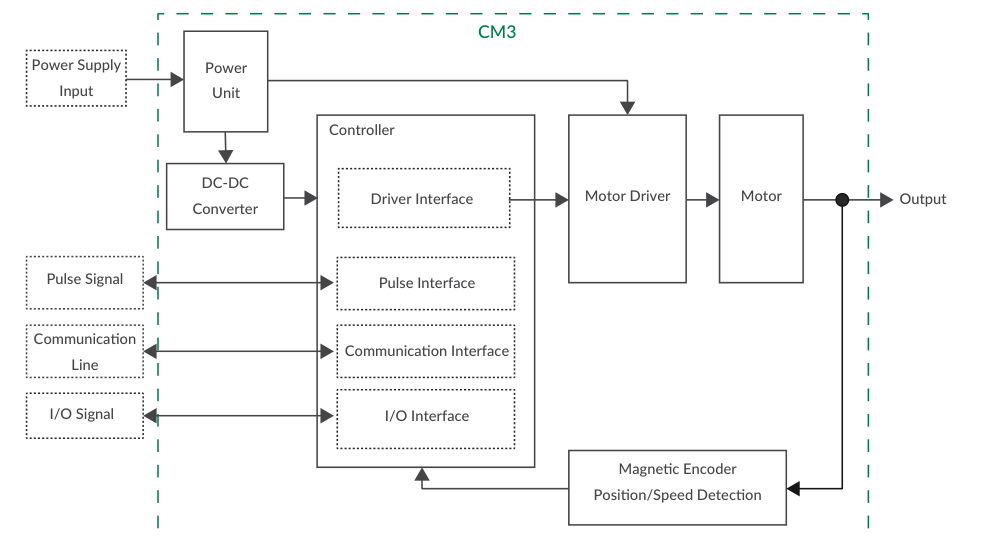
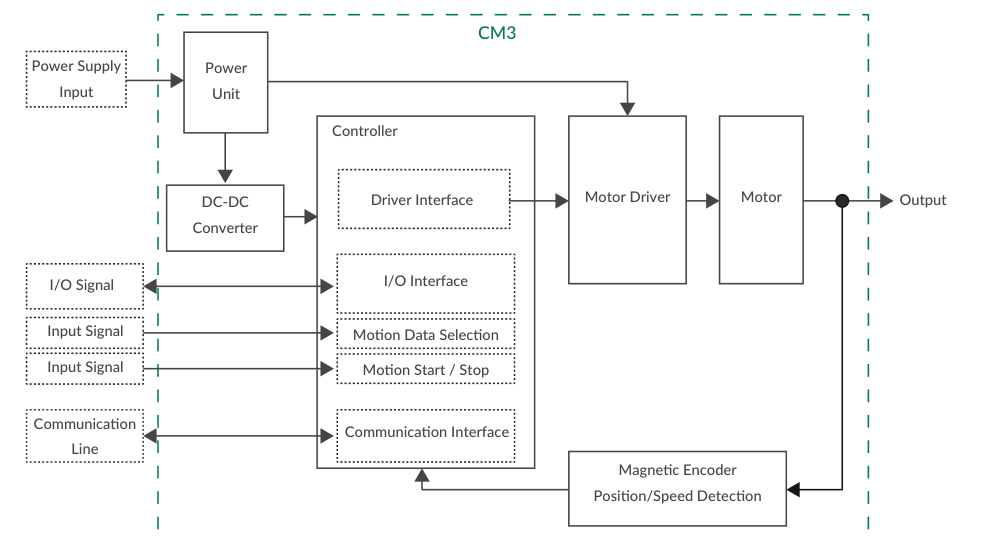
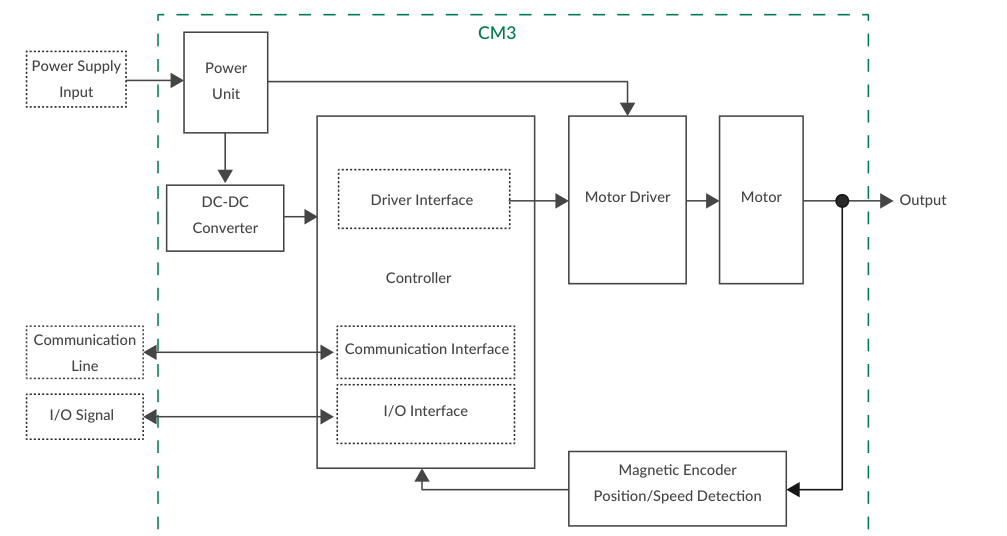
The function block diagram differs by control type.
Pulse Type
I/O Type
Direct Type
Parts Description
The names of parts of CM3 are as shown below.
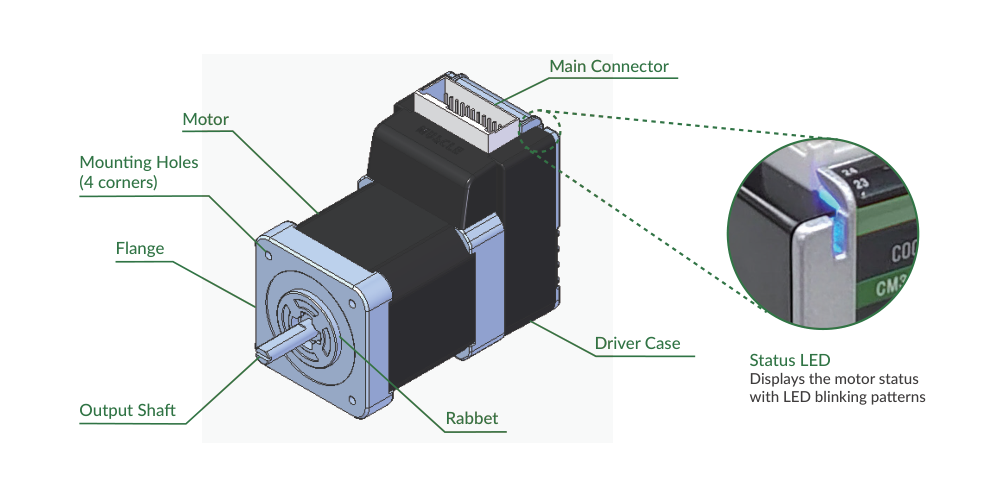
Please refer to Status LED on the Various Functions page for the status LED blinking pattern.
Rotating Direction and Coordinate
Rotating direction and coordinate are defined as below.
-
CW (Clockwise) Direction: Clockwise direction defined as viewed from output shaft side.
-
CCW (Counterclockwise) Direction: Counterclockwise direction defined as viewed from output shaft side.
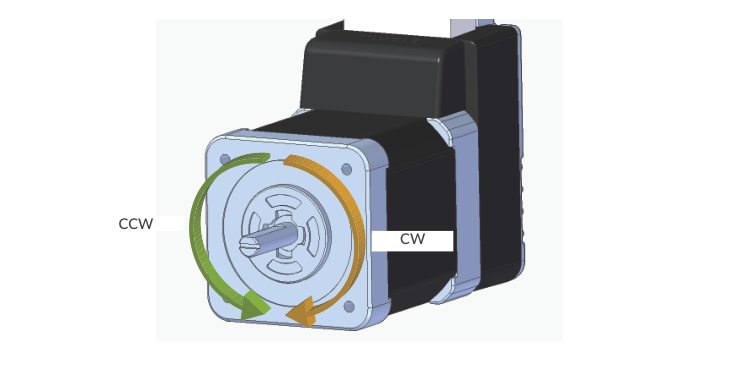
Coordinate Direction
By the default setting, CW direction is positive direction and CCW direction is negative direction in coordinate. On the I/O and Direct Types, the coordinate direction can be reversed by parameter. Ref: Coordinate Direction (K4) on the Detail of Various Settings page
Control
Pulse Type
The Pulse type CM3 operates by receiving pulse signals from a pulse generator such as a PLC. The pulse signal supports CW/CCW, step/direction, and AB phase, and its input can be connected by either the line driver method or the open collector method.
Refer to Positioning Operation on the Various Functions page for details.
I/O Type
The I/O type CM3 can select and execute up to 8 points of Motion Data set from the PC by input signals. Each Motion Data is composed of necessary items for motion such as speed, acceleration, target position, etc.
Refer to the Various Functions page for details.
Direct Type
The Direct type CM3 can be controlled by RS-232C serial communication. After setting A (Acceleration), S (Speed), P (Position), motion can be executed by execution command "^".
Ex. Move to Position 1000 with Acceleration 5, Speed 10:
S=10       //Set speed as 10
A=5        //Set acceleration as 5
P=1000     //Set target position as 1000
^          //Execution
Max. 32 Motion Data can be created. Each Motion Data is composed of necessary items for motion such as speed, acceleration, target position, etc. Motion starts when an execution command is sent after setting data in the specified Motion Data.
Refer to Positioning Operation on the Various Functions page for details.
Program Language, COOL MUSCLE Language CML
CML is an abbreviation for "COOL MUSCLE Language" (hereafter, CML) to operate/control CM3. CML consists of the following items.
Parameters
Parameters set the system conditions such as CM3's communication setting, alarm conditions and etc.
Motion Data
Motion Data set CM3 motion conditions from current position to target position.
Execution Commands
Execution commands are commands to execute preset content in CM3, save data, and turn on / off general output.
Query Commands
Query commands read CM3's current status (set value as position, speed etc).
CM3 Status
Current status (In-position, alarm, warning and etc) of CM3.
Pulse Type
Motion Data does not apply to the Pulse Type. On the Pulse Type, CML is used for setting and checking the status of CM3.
Please refer to Query Commands on the CML (COOL MUSCLE Language) page for Query commands and CM3 status. ".Motor ID" follows all CML but ".Motor ID" is not described in this document due to that CM3 is a single axis controlled device. ".Motor ID" is not necessary when sending CML to CM3 but ".Motor ID" is added in replied data.
Please use 1 byte character only. CML is not case sensitive.